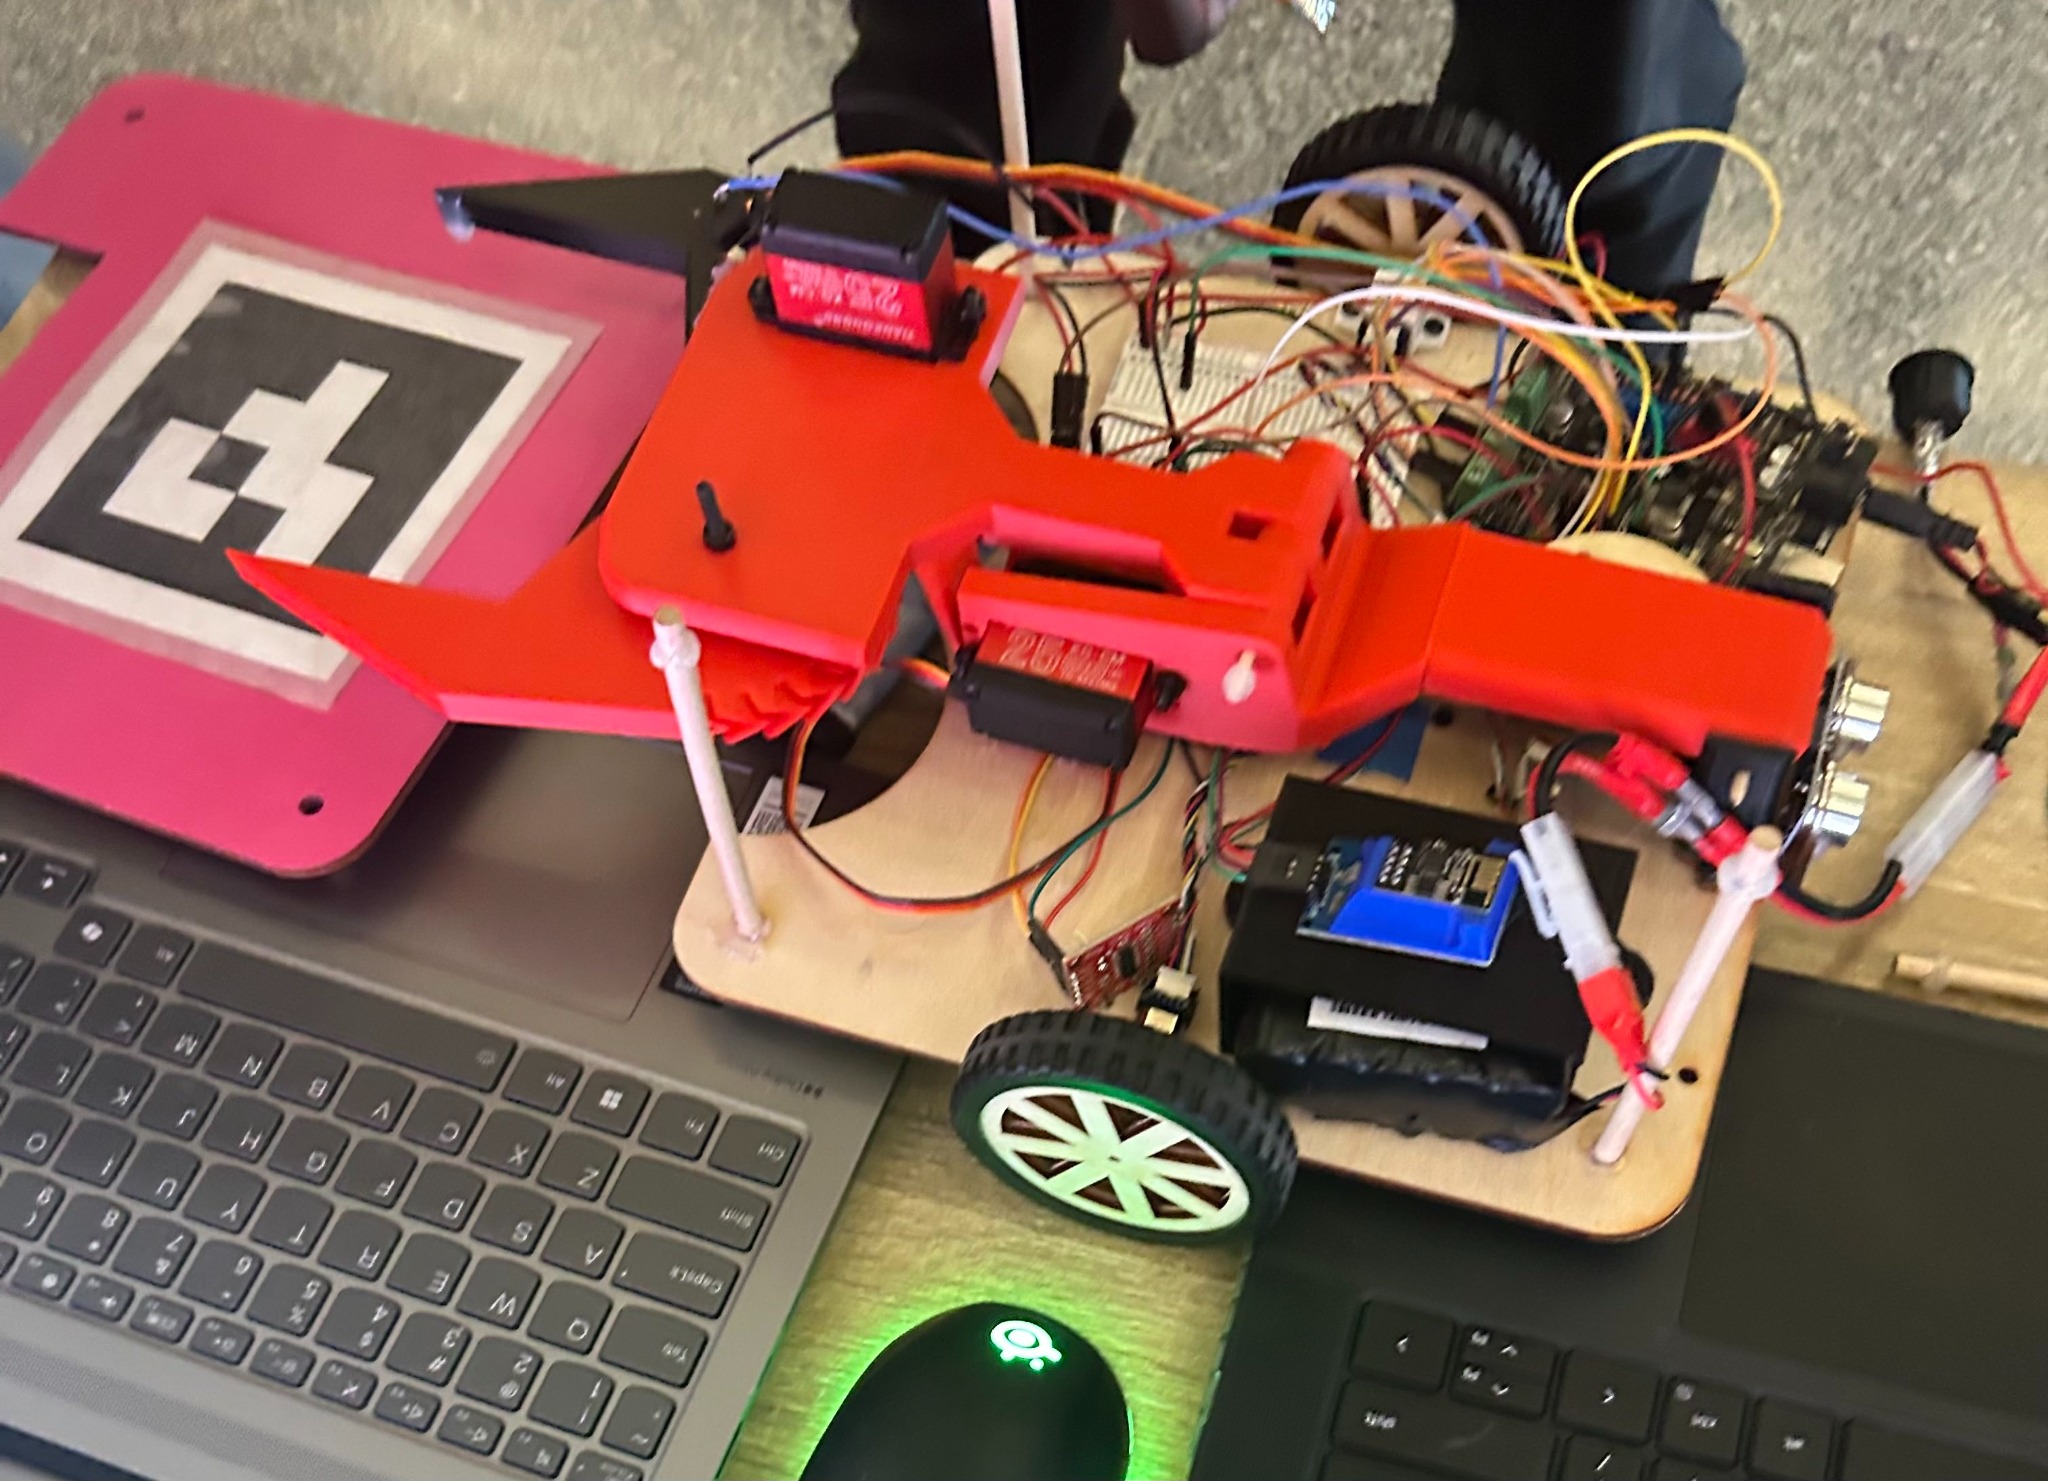
Autonomous Over-Terrain Vehicle
Engineered the propulsion subsystem for an autonomous vehicle, combining motor sizing, custom mounting, and Arduino-based motor control.
What
- Led an eight-person team in designing an autonomous over-terrain vehicle and directed propulsion development.
- Selected a motor and power system to meet vehicle performance requirements within the project constraints.
- Developed the propulsion subsystem from sizing calculations through custom mounting, electrical integration, and motor testing.
How
- Performed motor sizing and power calculations to evaluate the torque, speed, and current required for propulsion.
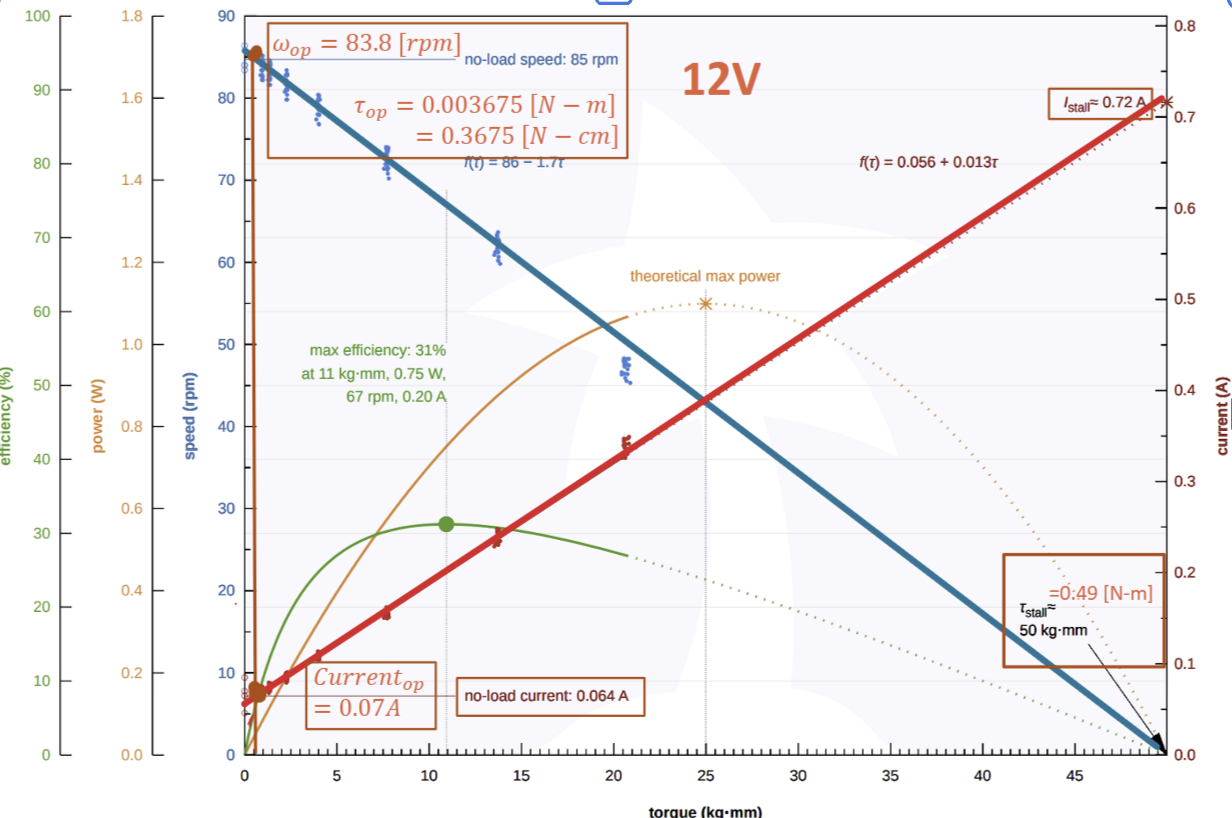
- Annotated the selected motor’s 12 V performance curves to identify the calculated operating point.
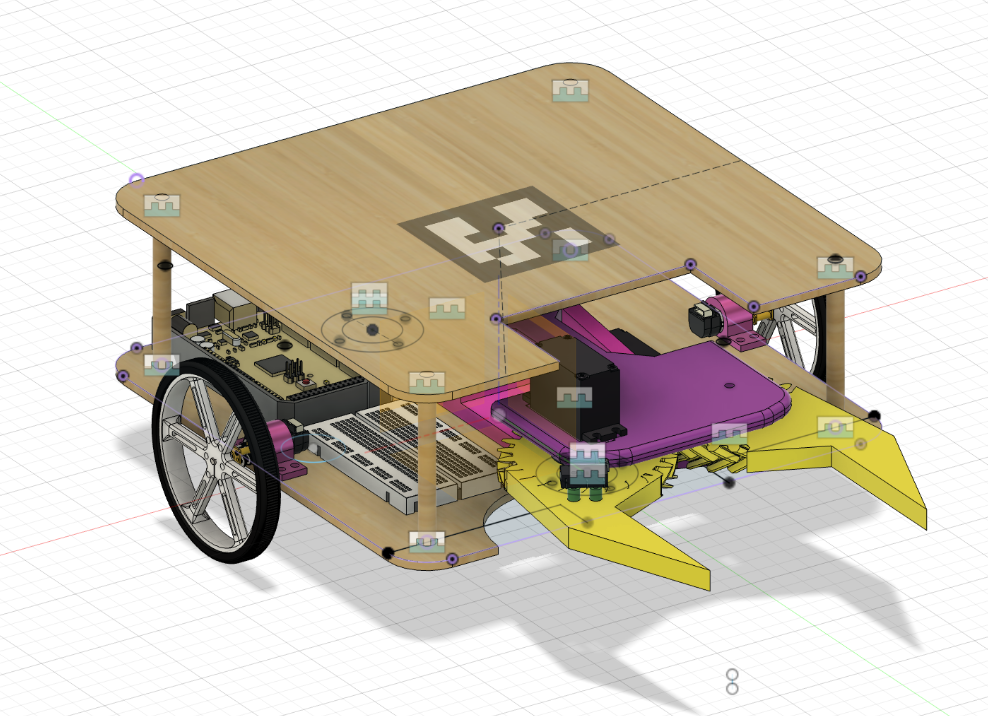
- Designed a custom motor housing in Autodesk Fusion and integrated the propulsion hardware into the chassis.
- Installed and wired Arduino-based motor controls and tested motor operation after assembly.
Results
- Calculated an operating point of approximately 83.8 rpm, 0.003675 N·m, and 0.07 A using the selected motor’s performance graph.
- Completed the custom motor housing and integrated the propulsion hardware into the vehicle chassis.
- Installed and tested the motor controls and wiring as part of subsystem integration.
- Delivered the propulsion assembly while leading an eight-person vehicle design team; documented the progression from CAD to assembled hardware.